About Me
Robotics engineer focused on building reliable, real-world robotic systems, with interests spanning 3D perception, motion planning, manipulation, and robot control. I work primarily with C++, ROS 2, and modern robotics tools to turn perception and planning algorithms into integrated systems that can sense, plan, and act in the physical world. I enjoy bridging algorithms and engineering — from point clouds and coordinate transformations to motion execution, system integration, and deployment.
Skills
Projects
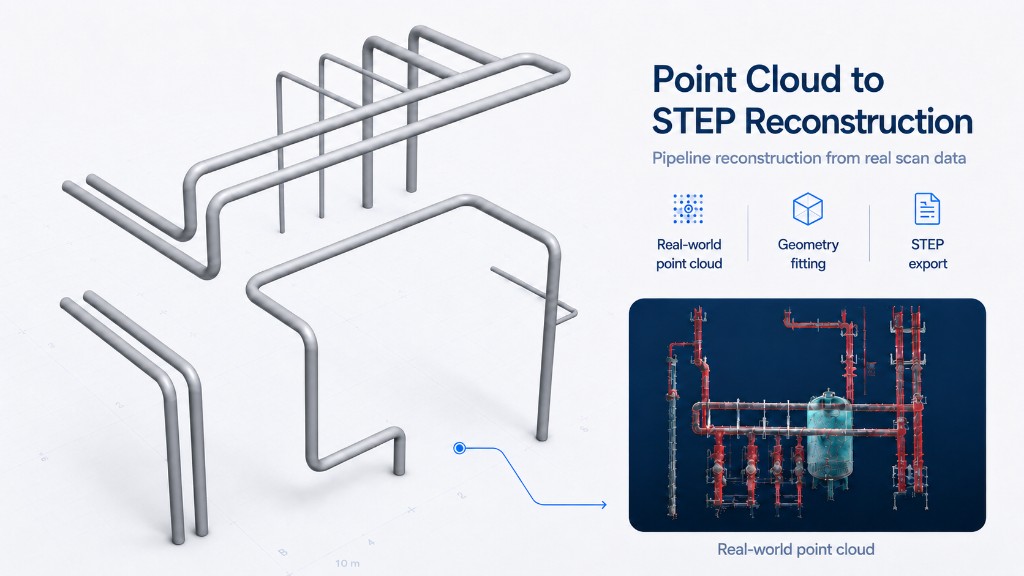
Point Cloud to STEP Reconstruction
Fully automated Scan-to-CAD pipeline for million-scale industrial point clouds. Reconstructs straight pipes, elbows, tees, and connectivity into STEP geometry for downstream Revit/BIM modeling.
Work Experience
Point Cloud Algorithm Engineer Intern
Jul 2026 - Oct 2026
- Independently developed a fully automated Scan-to-CAD pipeline for million-scale industrial point clouds, reconstructing straight pipes, elbows, tees, and connectivity into STEP geometry for downstream Revit/BIM modeling.
- Designed a multi-axis slice-tracking and topology-aware reconstruction algorithm for noisy, fragmented, and heavily occluded piping scenes, producing cleaner CAD primitives and substantially more complete reconstruction than EdgeWise on target industrial scans.
- Introduced HELIOS++ synthetic LiDAR simulation to generate controllable scans with known ground-truth geometry, enabling systematic validation and achieving complete recovery of all target piping components in synthetic test scenes.
- Parallelized slice-processing stages and accelerated geometric operations with C++/PCL, reducing end-to-end runtime on ~1M-point scans from 7–10 min to ~3 min.
Education
Bachelor of Engineering in Intelligent Science and Technology
Hangzhou Dianzi University
Sep 2024 - Present
Publications & Patents
A Coverage Path Planning Method and System for Free-Form Surfaces Based on Point Cloud Reconstruction
A Method and System for 3D Reconstruction of Animal Surfaces for Robotic Shearing
Honors & Awards
Zhejiang Provincial College Students' Science and Technology Innovation Program (Xinmiao Talent Program)
"Intelligent Sheep-Shearing Robot Based on Visuotactile Fusion and Biomimetic Reflex Architecture"
2nd "SUPCON Cup" Intelligent Manufacturing Challenge — National Finals, Third Prize
Team Member
Languages
Mandarin Chinese
Native
English
Professional Working